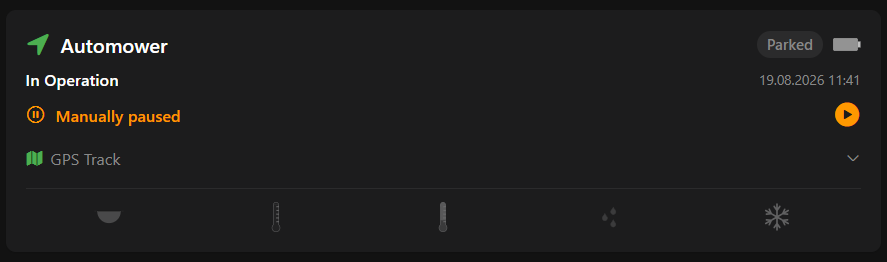
Hi @Ltty - Nice work - I had an initial look at this, and considering leveraging aspects for my local installation.
If you are interested, here are some suggestions:
- Download and serve up the unpkg components from your local OpenHAB server
- Ditto for downloading the Tiles, and serving them up from your OpenHAB server
I am definitely a fan of minimising dependencies on external systems/sites, so doing the above should help take these out of the mix, e.g. :
# Create directory tree
sudo -u openhab mkdir -p /etc/openhab/html/mower/leaflet/images
sudo -u openhab mkdir -p /etc/openhab/html/mower/tiles

# Download Leaflet JS and CSS (pinned to v1.9.4)
sudo -u openhab curl -sSL https://unpkg.com/leaflet@1.9.4/dist/leaflet.js -o /etc/openhab/html/mower/leaflet/leaflet.js
sudo -u openhab curl -sSL https://unpkg.com/leaflet@1.9.4/dist/leaflet.css -o /etc/openhab/html/mower/leaflet/leaflet.css

# Download standard Leaflet marker assets (referenced by leaflet.css)
sudo -u openhab curl -sSL https://unpkg.com/leaflet@1.9.4/dist/images/marker-icon.png -o /etc/openhab/html/mower/leaflet/images/marker-icon.png
sudo -u openhab curl -sSL https://unpkg.com/leaflet@1.9.4/dist/images/marker-icon-2x.png -o /etc/openhab/html/mower/leaflet/images/marker-icon-2x.png
sudo -u openhab curl -sSL https://unpkg.com/leaflet@1.9.4/dist/images/marker-shadow.png -o /etc/openhab/html/mower/leaflet/images/marker-shadow.png
Gemini threw together a file for downloading the tiles as follows:
import os
import math
import time
import urllib.request

# Bounding box derived from your KML polygon coordinates with a buffer
NORTH_LAT = -xx.yyyy
SOUTH_LAT = -xx.yyyy
WEST_LON  = xxx.yyyy
EAST_LON  = xxx.yyyy

# Zoom levels 17 (neighborhood), 18 (property), 19 & 20 (high-res yard level)
ZOOM_LEVELS = range(17, 21)

OUTPUT_DIR = "/etc/openhab/html/mower/tiles"
TILE_URL_TEMPLATE = "https://server.arcgisonline.com/ArcGIS/rest/services/World_Imagery/MapServer/tile/{z}/{y}/{x}"

def deg2num(lat_deg, lon_deg, zoom):
    lat_rad = math.radians(lat_deg)
    n = 2.0 ** zoom
    xtile = int((lon_deg + 180.0) / 360.0 * n)
    ytile = int((1.0 - math.asinh(math.tan(lat_rad)) / math.pi) / 2.0 * n)
    return (xtile, ytile)

count = 0
for z in ZOOM_LEVELS:
    x_min, y_min = deg2num(NORTH_LAT, WEST_LON, z)
    x_max, y_max = deg2num(SOUTH_LAT, EAST_LON, z)

    # In Web Mercator Y increases going south
    for x in range(min(x_min, x_max), max(x_min, x_max) + 1):
        for y in range(min(y_min, y_max), max(y_min, y_max) + 1):
            tile_dir = f"{OUTPUT_DIR}/{z}/{x}"
            os.makedirs(tile_dir, exist_ok=True)
            tile_path = f"{tile_dir}/{y}.jpg"

            if not os.path.exists(tile_path):
                url = TILE_URL_TEMPLATE.format(z=z, x=x, y=y)
                req = urllib.request.Request(url, headers={'User-Agent': 'Mozilla/5.0 (openHAB Yard Map Tile Downloader)'})
                try:
                    with urllib.request.urlopen(req) as resp, open(tile_path, 'wb') as f:
                        f.write(resp.read())
                    print(f"Downloaded tile: {z}/{x}/{y}.jpg")
                    count += 1
                    time.sleep(0.1) # Gentle throttling
                except Exception as e:
                    print(f"Failed to fetch {z}/{x}/{y}: {e}")
            else:
                print(f"Already exists: {z}/{x}/{y}.jpg")

print(f"\nDone! Downloaded {count} new tile(s) to {OUTPUT_DIR}")
Then a quick test (Generated by Gemini using your automower-map.html as the basis):
<!DOCTYPE html>
<html lang="en">
<head>
  <meta charset="utf-8">
  <meta name="viewport" content="width=device-width, initial-scale=1.0">
  <title>Automower Live Tracker</title>

  <!-- Locally hosted Leaflet CSS -->
  <link rel="stylesheet" href="leaflet/leaflet.css"/>

  <style>
    html, body {
      height: 100%;
      margin: 0;
      padding: 0;
      background: #1a1a2e;
      overflow: hidden;
      font-family: -apple-system, BlinkMacSystemFont, "Segoe UI", Roboto, sans-serif;
    }
    #map {
      width: 100%;
      height: 100vh;
      background: #1a1a2e;
    }
    #msg {
      position: absolute;
      inset: 0;
      display: flex;
      align-items: center;
      justify-content: center;
      color: #8888aa;
      font-size: 14px;
      pointer-events: none;
      z-index: 1000;
    }
    #status-overlay {
      position: absolute;
      top: 10px;
      right: 10px;
      background: rgba(26, 26, 46, 0.85);
      border: 1px solid rgba(255, 255, 255, 0.15);
      color: #e0e0e0;
      padding: 6px 12px;
      border-radius: 6px;
      font-size: 11px;
      line-height: 1.4;
      z-index: 999;
      pointer-events: none;
      backdrop-filter: blur(4px);
    }
  </style>
</head>
<body>

  <div id="map"></div>
  <div id="msg">Loading track…</div>
  <div id="status-overlay" style="display: none;"></div>

  <!-- Locally hosted Leaflet JS -->
  <script src="leaflet/leaflet.js"></script>

  <script>
    var params    = new URLSearchParams(window.location.search);
    var itemName  = params.get('item') || 'Automower_Location';
    var serviceId = params.get('serviceId') || 'influxdb';

    // Center of your property coordinates
    var YARD_CENTER = [-xx.xxxx, xxx.xxxx];

    // Bounding box from your polygon coordinates
    var YARD_BOUNDS = [
      [-xxx.yyyy, xxx.xxxx], // Southwest
      [-xxx.yyyy, xxx.xxxx]  // Northeast
    ];

    var map      = null;
    var marker   = null;
    var polyline = null;
    var path     = [];

    var MOWER_ICON = L.divIcon({
      html: '<svg xmlns="http://www.w3.org/2000/svg" width="26" height="26" viewBox="0 0 26 26"' +
            ' style="filter:drop-shadow(0 2px 5px rgba(0,0,0,0.7))">' +
            '<circle cx="5"  cy="5"  r="3.2" fill="#222" stroke="#fff" stroke-width="1.2"/>' +
            '<circle cx="21" cy="5"  r="3.2" fill="#222" stroke="#fff" stroke-width="1.2"/>' +
            '<circle cx="5"  cy="21" r="3.2" fill="#222" stroke="#fff" stroke-width="1.2"/>' +
            '<circle cx="21" cy="21" r="3.2" fill="#222" stroke="#fff" stroke-width="1.2"/>' +
            '<rect x="5" y="5" width="16" height="16" rx="3" fill="#4CAF50" stroke="#fff" stroke-width="1.5"/>' +
            '<circle cx="13" cy="13" r="3.5" fill="rgba(255,255,255,0.25)" stroke="rgba(255,255,255,0.6)" stroke-width="1"/>' +
            '</svg>',
      className: '',
      iconSize: [26, 26],
      iconAnchor: [13, 13]
    });

    function updateOverlay(lat, lon) {
      var overlay = document.getElementById('status-overlay');
      var now = new Date().toLocaleTimeString([], { hour: '2-digit', minute: '2-digit', second: '2-digit' });
      overlay.innerHTML = '<strong>' + itemName + '</strong><br>' +
                          lat.toFixed(6) + ', ' + lon.toFixed(6) + '<br>' +
                          '<span style="color:#888;">Updated: ' + now + '</span>';
      overlay.style.display = 'block';
    }

    function initMap(lat, lon) {
      document.getElementById('msg').style.display = 'none';
      if (map) return;

      var startLat = (lat !== undefined && lat !== null) ? lat : YARD_CENTER[0];
      var startLon = (lon !== undefined && lon !== null) ? lon : YARD_CENTER[1];

      map = L.map('map', {
        zoomControl: false,
        attributionControl: false,
        maxBounds: YARD_BOUNDS,
        maxBoundsViscosity: 0.8
      }).setView([startLat, startLon], 19);

      // Point directly to locally stored tiles
      L.tileLayer('tiles/{z}/{x}/{y}.jpg', {
        minZoom: 17,
        maxZoom: 21,
        maxNativeZoom: 20,
        errorTileUrl: ''
      }).addTo(map);

      window.addEventListener('resize', function() { map.invalidateSize(); });
      setTimeout(function() { map.invalidateSize(); }, 200);
    }

    function redraw() {
      if (!map || path.length === 0) return;
      var last = path[path.length - 1];

      if (polyline) map.removeLayer(polyline);
      if (path.length > 1) {
        polyline = L.polyline(path, {
          color: '#FF6B35',
          weight: 3,
          opacity: 0.9,
          lineJoin: 'round'
        }).addTo(map);
      }

      if (marker) map.removeLayer(marker);
      marker = L.marker([last[0], last[1]], { icon: MOWER_ICON }).addTo(map);
      updateOverlay(last[0], last[1]);
    }

    function parseState(text) {
      if (!text || text === 'NULL' || text === 'UNDEF') return null;
      var parts = text.trim().split(',');
      if (parts.length < 2) return null;
      var lat = parseFloat(parts[0]);
      var lon = parseFloat(parts[1]);
      return isNaN(lat) || isNaN(lon) ? null : [lat, lon];
    }

    function todayMidnightISO() {
      var d = new Date();
      d.setHours(0, 0, 0, 0);
      return d.toISOString();
    }

    function fetchHistory() {
      if (!itemName) {
        initMap(YARD_CENTER[0], YARD_CENTER[1]);
        return;
      }

      var url = '/rest/persistence/items/' + encodeURIComponent(itemName) +
                '?starttime=' + encodeURIComponent(todayMidnightISO()) +
                '&serviceId=' + encodeURIComponent(serviceId) +
                '&boundary=false';

      fetch(url)
        .then(function(r) { return r.ok ? r.json() : Promise.reject(r.status); })
        .then(function(data) {
          var pts = (data.data || []).map(function(d) { return parseState(d.state); })
                                     .filter(function(p) { return p !== null; });

          if (pts.length === 0) {
            document.getElementById('msg').textContent = 'No movement recorded today';
            fetchPosition();
            return;
          }

          path = pts;
          var last = path[path.length - 1];
          initMap(last[0], last[1]);
          redraw();
          map.fitBounds(L.polyline(path).getBounds(), { padding: [25, 25], maxZoom: 19 });
        })
        .catch(function() {
          fetchPosition();
        });
    }

    function fetchPosition() {
      if (!itemName) return;

      fetch('/rest/items/' + encodeURIComponent(itemName) + '/state', { headers: { Accept: 'text/plain' } })
        .then(function(r) { return r.ok ? r.text() : Promise.reject(r.status); })
        .then(function(text) {
          var pos = parseState(text);
          if (!pos) {
            initMap(YARD_CENTER[0], YARD_CENTER[1]);
            return;
          }

          initMap(pos[0], pos[1]);

          var last = path[path.length - 1];
          var moved = !last || Math.abs(last[0] - pos[0]) > 0.000005 || Math.abs(last[1] - pos[1]) > 0.000005;

          if (!moved) return;

          path.push(pos);
          redraw();
          map.panTo([pos[0], pos[1]]);
        })
        .catch(function() {
          initMap(YARD_CENTER[0], YARD_CENTER[1]);
        });
    }

    fetchHistory();
    setInterval(fetchPosition, 30000);
  </script>
</body>
</html>
As a basic test, for running locally, seems to work to display current position (Will have to wait a day or 2 to see history, as I only enabled persistence on that item tonight).
Have a look at Automower (Husqvarna) MainUI Page to see an approach I used to allow basic configuration and control of the mower.
You could consider using the Rule I created there, which creates a synthetic status item, which aligns mostly to what you would see in the Husqvarna app itself. It’s a bit friendlier than the raw items they present you !! Feel free to use this with your widget if you like.